Ainekio · build journal

Building a robot familiar

A four-legged companion in development: conversation, personality and memory connected to a body that can see, hear, move and express itself.

MetaHuman OS connects its decisions, experiences and learning. The current twelve-servo P4 body and original eight-servo S3 build are both documented here.

Start here →
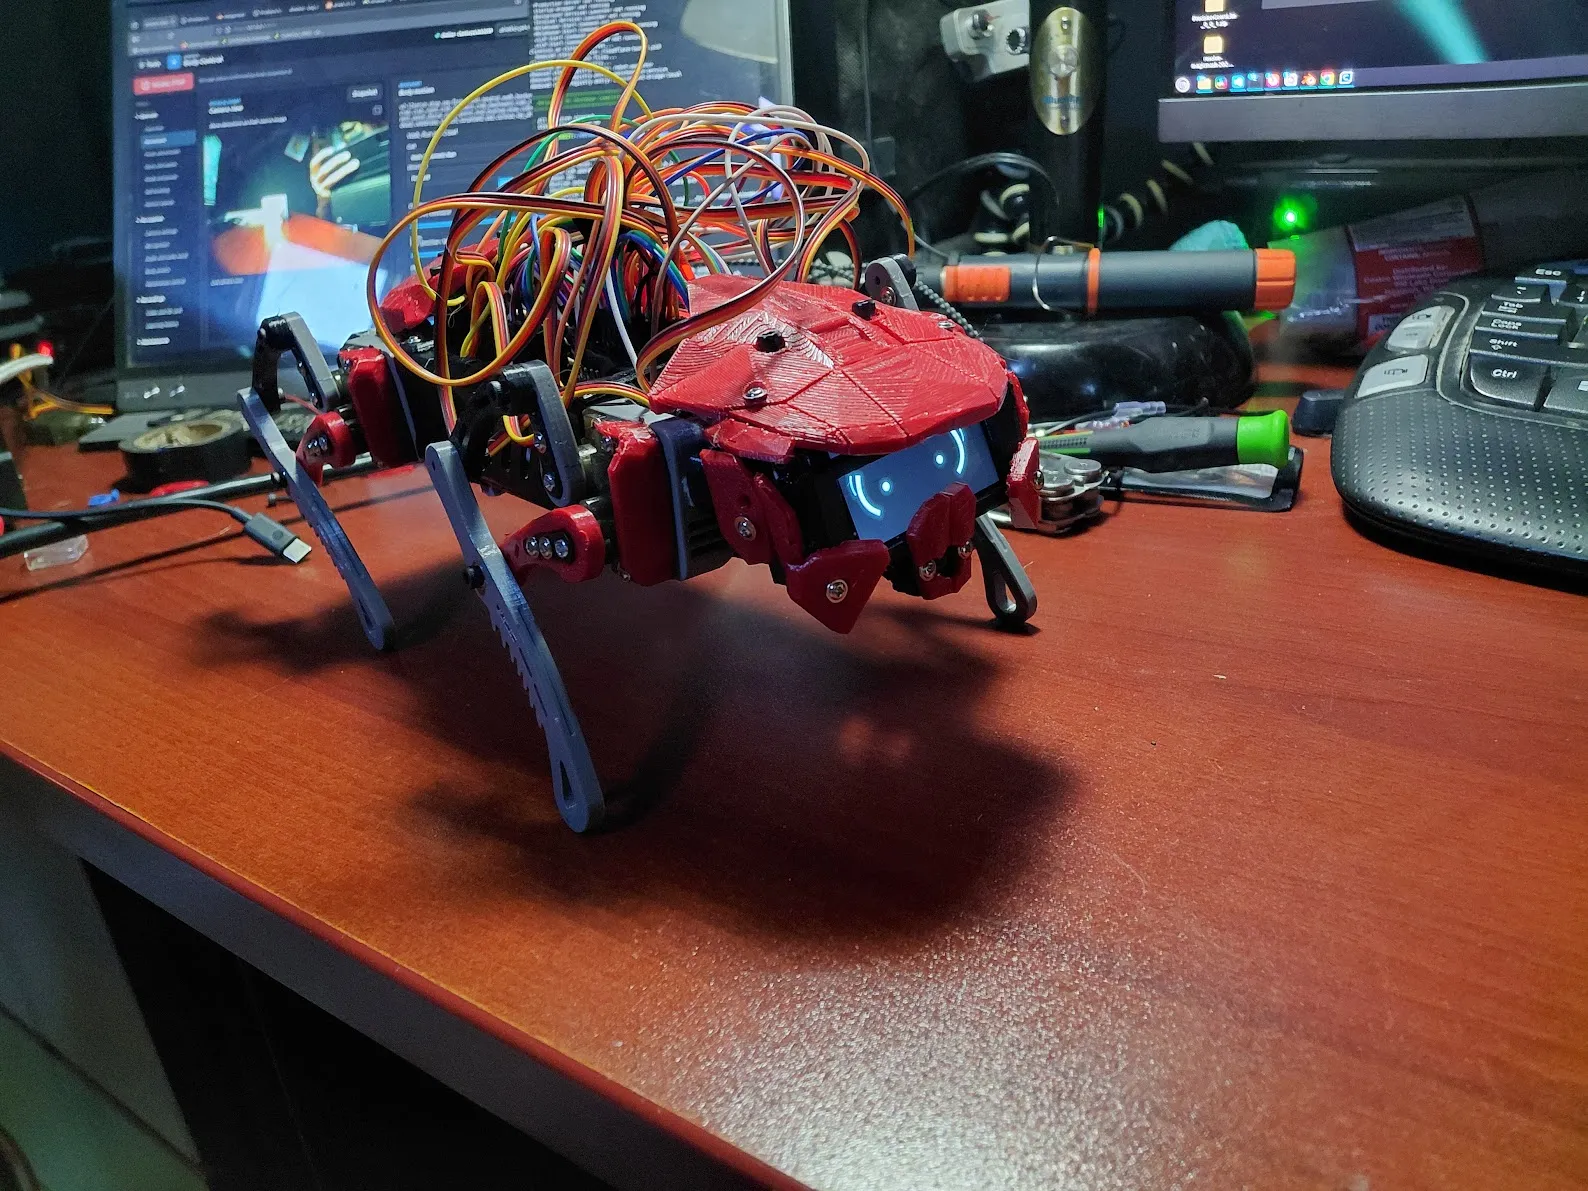
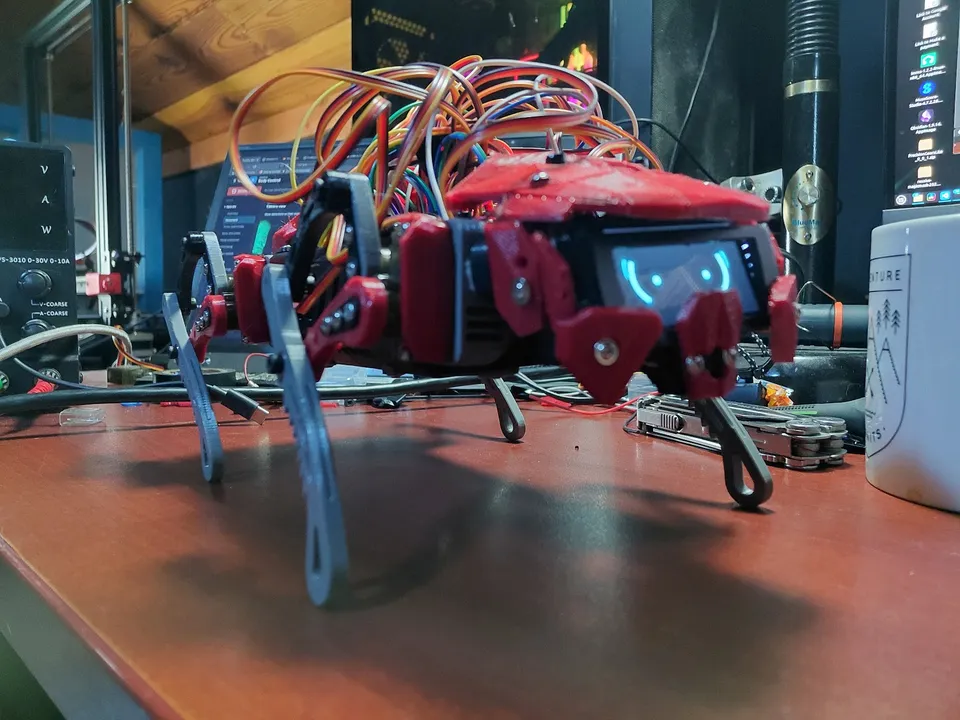
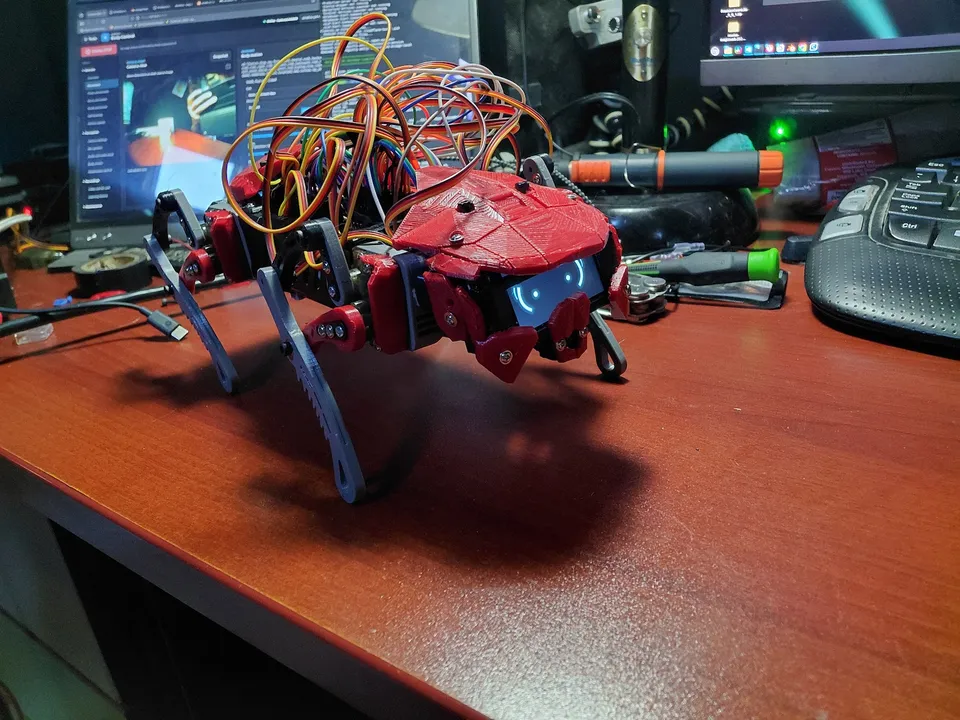
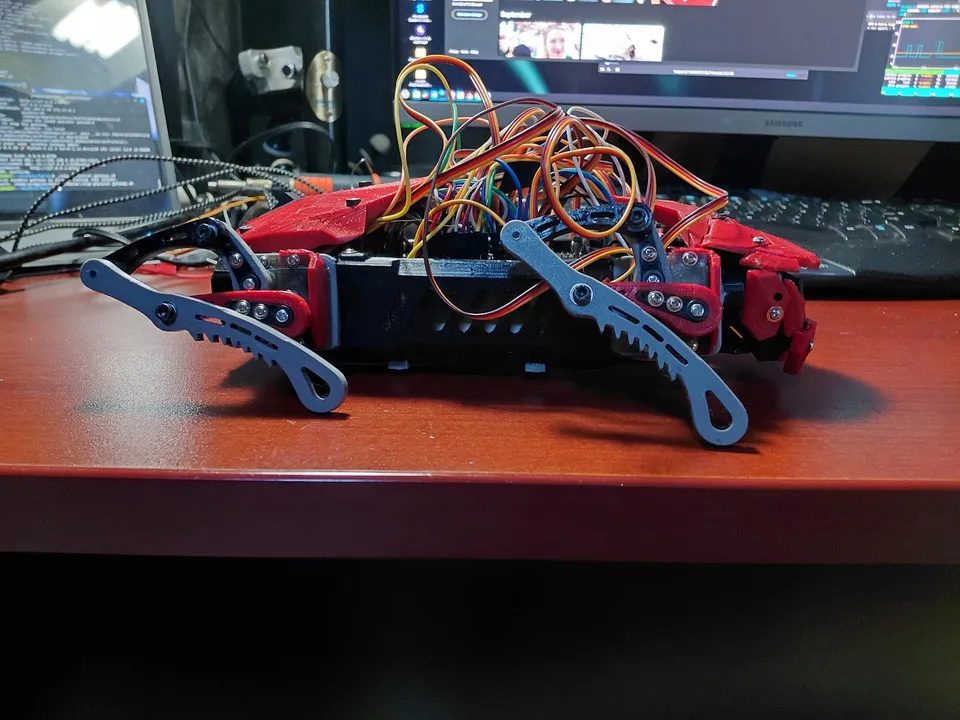
The assembled V2 prototype on the October 21 workbench, with its red face surround, illuminated display and exposed upper wiring.
The rebuilt V2 prototype, October 21. See the latest rebuild and videos →

Project status

650 g build, finite Freestyle motion and a supported stretch

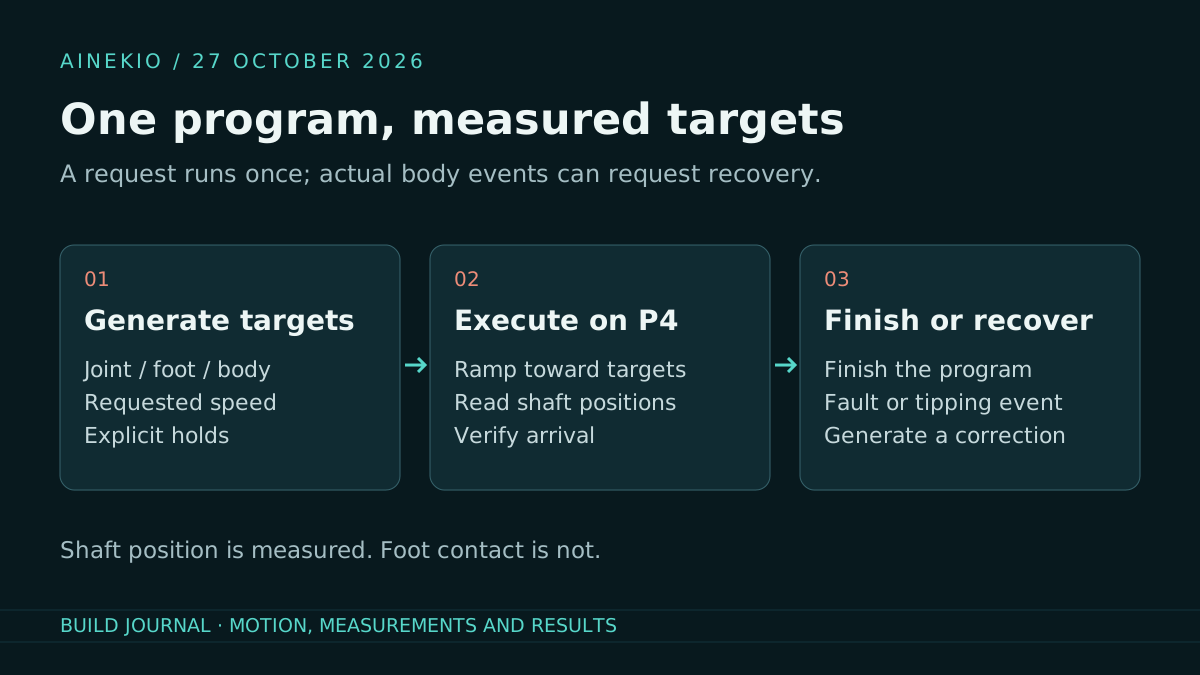
The current build is recorded at 650 g with a 2S battery, Mini560 converter and USB-C charger. Freestyle now runs a finite program once and uses actual body events for recovery. The October 27 model is activated on the workstation; a separate supported stretch verified all nine targets. Release choices, general stretch calibration, loaded motion and sustained Full Auto initiative remain unfinished.

Status and next steps →

The real robot, its rebuild, and the experiments behind it.

Explore photos and videos →

Latest from the workbench

Read the build journal →

· V2 · 12 servos

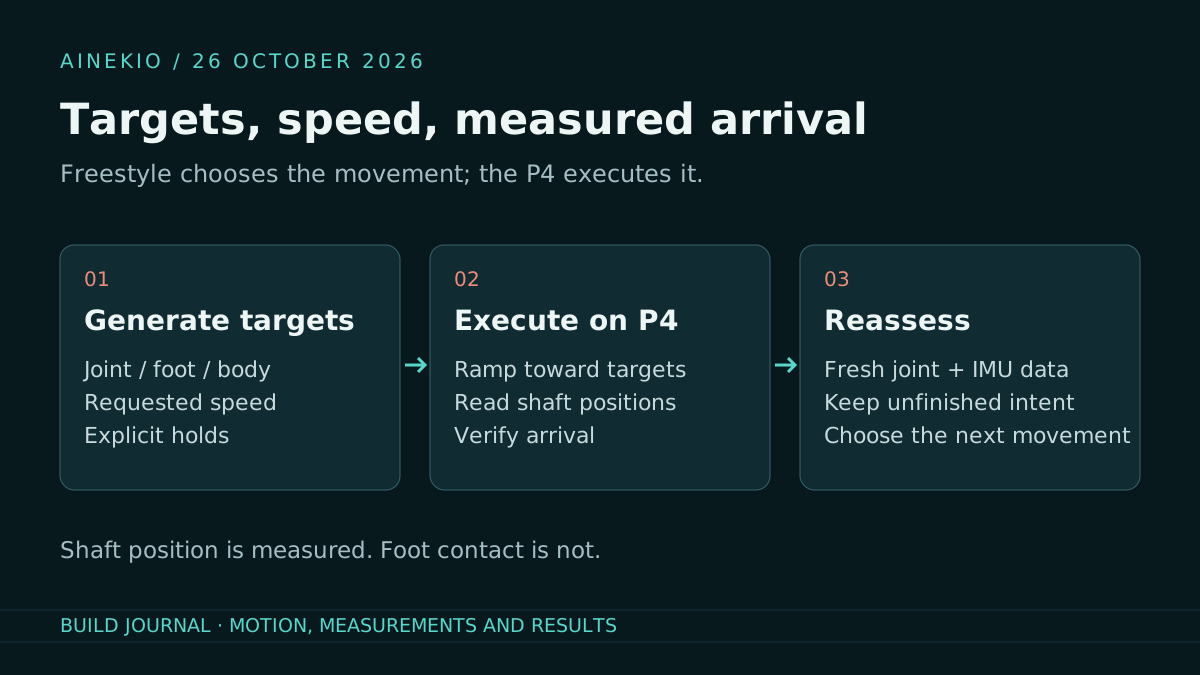
Freestyle: teaching targets, speed and recovery

Compact motion programs, measured shaft arrival and reviewed gesture corrections lead into a 1,261-example Stand training run. Reference agreement improves, but acquiring Stand and finishing compound movements remain difficult.

Explore by topic

Build reference →
Original Ainekio illustration: the eight-servo robot as a familiar in a wizard's workshop

Where the build began

The original eight-servo robot

The original parts lists, design notes, firmware, and software experiments.

Read the original build journal →